Skip to main content
Precalculus
나의 코스
배우기
시험 준비
AI 튜터
학습 가이드
플래시카드
탐험해 보세요
앱을 사용해 보세요
나의 코스
배우기
시험 준비
AI 튜터
학습 가이드
플래시카드
탐험해 보세요
앱을 사용해 보세요
뒤로
Precalculus - Vectors, Complex Numbers, Linear Systems, Matrices, and Determinants
카드를 뒤집기 위해 탭할 수 있습니다.
Definition of a vector in the plane
카드를 뒤집기 위해 탭할 수 있습니다.
👆
Definition of a vector in the plane
A vector in the plane is a directed line segment with magnitude and direction, represented algebraically as an ordered pair (x, y).
진행 상황 추적
컨트롤 버튼이 '내비게이션' 모드로 변경되었습니다.
1/25
추천 영상
05:05
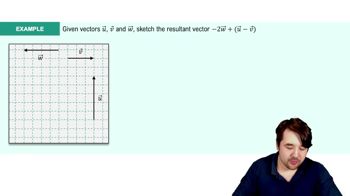
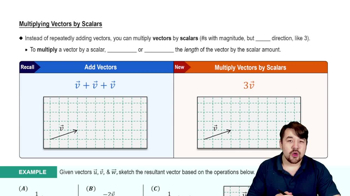
Multiplying Vectors By Scalars
597
views
15
rank
03:12
Multiplying Vectors By Scalars Example 1
492
views
16
rank
1
comments
05:29
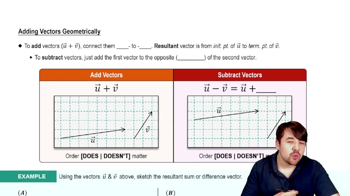
Adding Vectors Geometrically
713
views
17
rank
이 집합의 용어 (25)
하이드의 정의
Definition of a vector in the plane
A vector in the plane is a directed line segment with magnitude and direction, represented algebraically as an ordered pair (x, y).
Vector addition in R2
Sum of vectors (a, b) + (c, d) = (a + c, b + d), commutative and associative.
Scalar multiplication of vectors
For vector (a, b) and scalar α, α(a, b) = (αa, αb).
Dot product of vectors in R2
For u = (u1, u2) and v = (v1, v2), u · v = u1v1 + u2v2, a scalar.
Angle between two vectors
cos θ = (u · v) / (∥u∥ ∥v∥), where θ is the angle between nonzero vectors u and v.
Complex number standard form
z = a + bi, where a, b ∈ R and i² = -1.
Complex conjugate and modulus
Conjugate of z = a + bi is z̄ = a - bi; modulus |z| = √(a² + b²).
Multiplication of complex numbers
(a + bi)(c + di) = (ac - bd) + (ad + bc)i.
Polar (modulus-argument) form of complex numbers
z = r(cos θ + i sin θ) = r e^{iθ}, where r = |z| and θ = arg z.
De Moivre's Theorem
(cos θ + i sin θ)^n = cos(nθ) + i sin(nθ) for integer n.
nth roots of a complex number
The n distinct nth roots of z = r e^{iθ} are z_k = r^{1/n} e^{i(θ + 2πk)/n}, k = 0,...,n-1.
System of linear equations matrix form
AX = B, where A is coefficient matrix, X vector of unknowns, B vector of constants.
Elementary row operations
Operations: multiply row by nonzero scalar, interchange rows, add multiple of one row to another.
Reduced row-echelon form
Matrix form with leading 1s, zeros below and above leading 1s, zero rows at bottom.
Matrix addition and scalar multiplication
Add matrices element-wise; multiply each element by scalar.
Matrix multiplication condition
Product AB defined if columns of A = rows of B; result is matrix with rows of A and columns of B.
Transpose of a matrix
Transpose AT of matrix A is obtained by swapping rows and columns.
Invertible matrix and inverse
Square matrix A is invertible if ∃ B such that AB = BA = I; B = A^{-1}.
Determinant of 2x2 matrix
det(A) = ad - bc for A = [[a, b], [c, d]].
Cofactor expansion for determinant
det(A) = sum of elements of any row or column times their cofactors.
Cramer's Rule
Solution x_j = det(A_j) / det(A), where A_j replaces j-th column of A with constants vector.
Vector equation of a line in R3
r = a + λd, where a is a point on the line and d is a direction vector.
Dot product and angle between vectors
a · b = ∥a∥∥b∥ cos θ, where θ is the angle between vectors a and b.
Cross product of vectors in R3
a × b = (a2b3 - a3b2, a3b1 - a1b3, a1b2 - a2b1), orthogonal to both a and b.
Equation of a plane in R3
n · (r - a) = 0 or n1x + n2y + n3z = d, where n is normal vector and a is a point on the plane.
 뒤로뒤로
 05:05