Ch. 02 - Describing Motion: Kinematics in One Dimension
Giancoli Douglas - Physics for Scientists and Engineers 5th edition
Giancoli Douglas5th editionPhysics for Scientists and EngineersISBN: 9780137488179Non è quello che usi tu?Cambia libro di testo
Capitolo 2, Problema 99

A robot used in a pharmacy picks up a medicine bottle at t = 0. It accelerates at 0.20 m/s² for 4.5 s, then travels without acceleration for 68 s and finally decelerates at ―0.40 m/s² for 2.5 s to reach the counter where the pharmacist will take the medicine from the robot. From how far away did the robot fetch the medicine?

Guida verificata passo dopo passo
1
Step 1: Break the motion into three distinct phases: (1) acceleration, (2) constant velocity, and (3) deceleration. For each phase, calculate the distance traveled using the appropriate kinematic equations.
Step 2: For the acceleration phase, use the equation for distance under constant acceleration: d=vi0t+12at2. Here, vi0 is 0 m/s, a is 0.20 m/s², and t is 4.5 s. Substitute these values to find the distance traveled during this phase.
Step 3: For the constant velocity phase, first calculate the velocity at the end of the acceleration phase using the equation v=vi0+at. Then, use the equation d=vt to calculate the distance traveled during the 68 s of constant velocity.
Step 4: For the deceleration phase, use the equation d=vi0t+12at2. Here, vi0 is the velocity at the end of the constant velocity phase, a is -0.40 m/s², and t is 2.5 s. Substitute these values to find the distance traveled during this phase.
Step 5: Add the distances from all three phases to find the total distance traveled by the robot. This total distance represents how far away the robot fetched the medicine.

Risposta video verificata per un problema simile:

Questa soluzione video è stata consigliata dai nostri tutor come utile per risolvere questo problema.

Concetti chiave

Ecco i concetti essenziali che devi comprendere per rispondere correttamente alla domanda.

Kinematics

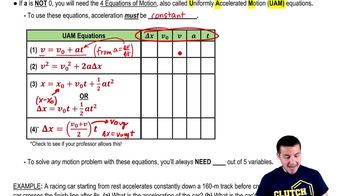
Kinematics is the branch of mechanics that describes the motion of objects without considering the forces that cause the motion. It involves concepts such as displacement, velocity, and acceleration. In this problem, understanding how to calculate the distance traveled during different phases of motion (acceleration, constant speed, and deceleration) is essential for determining the total distance the robot traveled.
Video consigliato:
Percorso guidato
08:25
Kinematics Equations

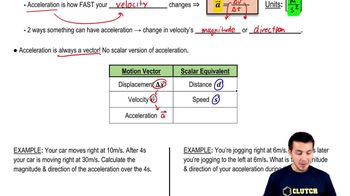
Acceleration

Acceleration is the rate of change of velocity of an object with respect to time. It can be positive (speeding up) or negative (decelerating). In this scenario, the robot experiences both positive acceleration (0.20 m/s²) and negative acceleration (−0.40 m/s²), which are crucial for calculating the distance covered during each phase of its journey.
Video consigliato:
Percorso guidato
05:47
Intro to Acceleration

Equations of Motion

The equations of motion relate an object's displacement, initial velocity, final velocity, acceleration, and time. These equations allow us to calculate the distance traveled during each phase of the robot's movement. For instance, the equation s = ut + 0.5at² can be used to find the distance during acceleration and deceleration, while the distance during constant speed can be calculated using s = vt.
Video consigliato:
Percorso guidato
07:18
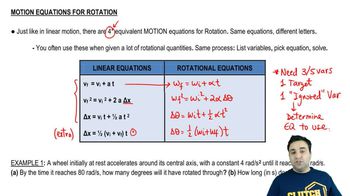
Equations of Rotational Motion